AGE-MOEA
Adaptive geometry estimation uses an estimated non-Euclidean front geometry to support diversity selection in many-objective search [1]. Three-objective DTLZ2 provides a small, inspectable demonstration.
Goal: run the stable public API in VAMOS 1.0.1, interpret its returned population, and identify which settings control this mechanism.
Capability matrix · Exact configuration reference · Setup and recorded evidence
Run the example
Prerequisite: complete T01 and the coverage setup. The protocol uses DTLZ2, 12 real variables, 3 objectives, population 40; 400 evaluations; NumPy; seed 42. Initial evaluations count towards the budget. Settings are illustrative, not tuned.
python agemoea.py
python agemoea.py --output agemoea-local.svg
The second command reruns the same protocol and requires Matplotlib. Use a new filename.
Complete runnable script
"""Verified VAMOS 1.0.1 lesson: agemoea. See coverage-setup for dependencies."""


def execute_example(problem, algorithm, config, budget, seed=42, engine="numpy"):
    import numpy as np

    from vamos import OptimizationResult, optimize

    result = optimize(problem, algorithm=algorithm, algorithm_config=config, max_evaluations=budget, seed=seed, engine=engine)
    G = result.data.get("G")
    if getattr(problem, "n_constraints", 0) and G is None:
        raise ValueError("Declared constraints are missing from the returned result.")
    feasible_rows = np.arange(len(result.F)) if G is None else np.flatnonzero(np.all(G <= 0, axis=1))
    if len(feasible_rows):
        feasible = OptimizationResult({"X": result.X[feasible_rows], "F": result.F[feasible_rows]})
        front, local = feasible.front(return_indices=True)
        front_rows = feasible_rows[local]
    else:
        front, front_rows = np.empty((0, problem.n_obj)), np.empty(0, dtype=int)
    print(f"Algorithm: {algorithm}; encoding: {problem.encoding}; backend: {engine}; seed: {seed}")
    print(f"Returned X: {result.X.shape}; F: {result.F.shape}; result mode: population")
    print(f"Feasible rows: {len(feasible_rows)}/{len(result.F)}; feasible non-dominated rows: {len(front)}")
    print(f"Evaluations: {result.data['evaluations']}")
    return {
        "problem": problem,
        "algorithm": algorithm,
        "config": config,
        "result": result,
        "feasible_rows": feasible_rows,
        "front": front,
        "front_rows": front_rows,
    }


def run_agemoea(budget=400):
    from vamos.algorithms import AGEMOEAConfig
    from vamos.problems import DTLZ2

    problem = DTLZ2(n_var=12, n_obj=3)
    config = (
        AGEMOEAConfig.builder()
        .pop_size(40)
        .crossover("sbx", prob=0.9, eta=15.0)
        .mutation("pm", prob=1.0 / problem.n_var, eta=20.0)
        .constraint_mode("feasibility")
        .result_mode("population")
        .build()
    )
    return execute_example(problem, "agemoea", config, budget)


def plot_example(data, output):
    from pathlib import Path

    import matplotlib

    matplotlib.use("Agg")
    import matplotlib.pyplot as plt
    import numpy as np

    output = Path(output)
    if output.exists():
        raise FileExistsError(f"Choose a new figure filename: {output}")
    if output.suffix.lower() != ".svg":
        raise ValueError("Use an .svg output filename.")
    f = data["result"].F
    with plt.rc_context({"svg.hashsalt": "vamos-coverage", "svg.fonttype": "none"}):
        fig = plt.figure(figsize=(7, 4.5), layout="constrained")
        if f.shape[1] == 3:
            ax = fig.add_subplot(projection="3d")
            ax.scatter(*f.T, c="#007f7a", s=22)
            ax.set(xlabel="f1", ylabel="f2", zlabel="f3")
            ax.set_box_aspect((1, 1, 0.85), zoom=0.85)
        else:
            ax = fig.add_subplot()
            ax.scatter(*f.T, c="#b6bec8", s=25, label="Returned population")
            if len(data["front"]):
                ax.scatter(*data["front"].T, c="#007f7a", s=30, label="Feasible non-dominated rows")
            labels = {
                "WeldedBeamDesignProblem": ("Cost (minimize)", "Deflection proxy (minimize)"),
                "FeatureSelectionProblem": ("Validation error (minimize)", "Feature count (minimize)"),
                "HyperparameterTuningProblem": ("Validation error (minimize)", "Complexity proxy (minimize)"),
            }
            xlabel, ylabel = labels.get(type(data["problem"]).__name__, ("f1 (minimize)", "f2 (minimize)"))
            ax.set(xlabel=xlabel, ylabel=ylabel)
            ax.legend()
        if data["problem"].__class__.__name__ in {"ZDT1", "ZDT1Problem"}:
            x = np.linspace(0, 1, 101)
            ax.plot(x, 1 - np.sqrt(x), "--", c="#7c8795", label="Analytical front")
            ax.legend()
        ax.set_title(f"{data['algorithm'].upper()} · {data['result'].data['evaluations']} evaluations · seed 42")
        fig.savefig(output, metadata={"Date": None}, bbox_inches="tight", pad_inches=0.25)
        plt.close(fig)
    output.write_text("\n".join(line.rstrip() for line in output.read_text(encoding="utf-8").splitlines()) + "\n", encoding="utf-8")


def lesson_cli(function, default_budget=400):
    import argparse

    parser = argparse.ArgumentParser(description="Run a bounded VAMOS example and optionally plot its actual result.")
    parser.add_argument("--budget", type=int, default=default_budget)
    parser.add_argument("--output", help="New SVG filename; requires Matplotlib")
    args = parser.parse_args()
    data = function(budget=args.budget)
    if args.output:
        plot_example(data, args.output)


if __name__ == "__main__":
    lesson_cli(run_agemoea, default_budget=400)
Recorded output
Algorithm: agemoea; encoding: real; backend: numpy; seed: 42
Returned X: (40, 12); F: (40, 3); result mode: population
Feasible rows: 40/40; feasible non-dominated rows: 40
Evaluations: 400
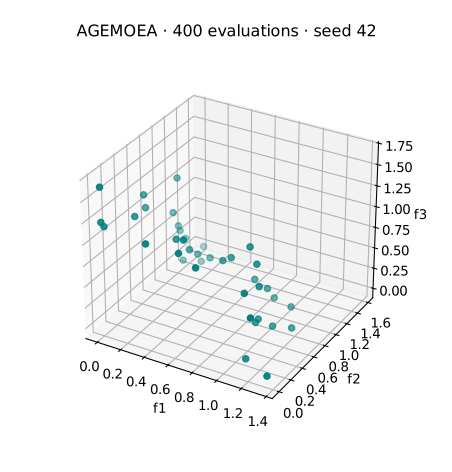
Measured with VAMOS 1.0.1; the observations and provenance retain the inputs and results.
Understand the configuration
| Setting | Meaning in this example |
|---|---|
| Population 40 | Does not require the simplex direction/population matching used by NSGA-III and RVEA. |
| SBX probability 0.9, eta 15 | Real-coded recombination in this explicit example. |
| Polynomial mutation | Numeric probability 1/12, eta 20. |
constraint_mode("feasibility") |
Enables the 1.0.1 feasibility path if constraints exist; DTLZ2 here is unconstrained. |
Interpret the result and its limits
Each X row aligns with the same F row. This lesson explicitly requests population mode, then computes the feasible non-dominated subset separately. All objectives are minimized. A non-dominated row is only non-dominated among the available rows; it need not be Pareto optimal. The retained observations contain the actual arrays and configuration.
Many returned points can be mutually non-dominated while still far from the true front. For this DTLZ2 formulation, ideal-front points are on the positive unit sphere; inspect distance to that surface as well as visual coverage. The scatter plot alone does not establish convergence or performance on larger objective counts.
This run has no constraints. Before using a constrained or discrete problem, check the capability matrix and constraint convention. Preserve complete runs through the canonical lifecycle; the teaching JSON is not a replay bundle.
Try one controlled change
Increase the budget to 800 while holding the problem and population fixed. Examine whether objective-vector norms approach one, then repeat seeds. Changing the objective count changes the problem and the meaning of the figure.
Next: use T06 to turn this example into a reproducible comparison.
References
[1] Panichella, A. (2019). An Adaptive Evolutionary Algorithm based on Non-Euclidean Geometry for Many-objective Optimization. GECCO 2019.